Journal Papers | Conference Papers | Workshop Papers | Theses | Technical Notes
My research has been published / presented in the following journals / conferences:
- Journals: IEEE T-RO (3), IJRR (2), Automatica (1)
- Conferences: RSS (2), WAFR (2), ICRA (5), IROS (2)
Please see below for papers, theses, preprints, presentations, and research software.
Journal Papers
- Distributed Certifiably Correct Pose-Graph Optimization –

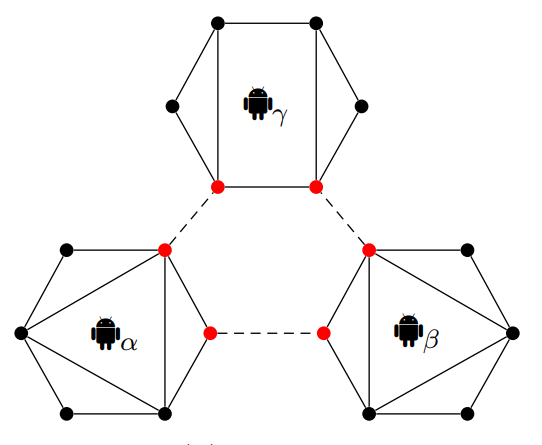
Y. Tian, K. Khosoussi, D.M. Rosen, and J.P. How
IEEE Transactions on Robotics (T-RO) 2021 — Conditionally Accepted
- A Resource-Aware Approach to Collaborative Loop Closure Detection with Provable Performance Guarantees –
Y. Tian, K. Khosoussi, and J.P. How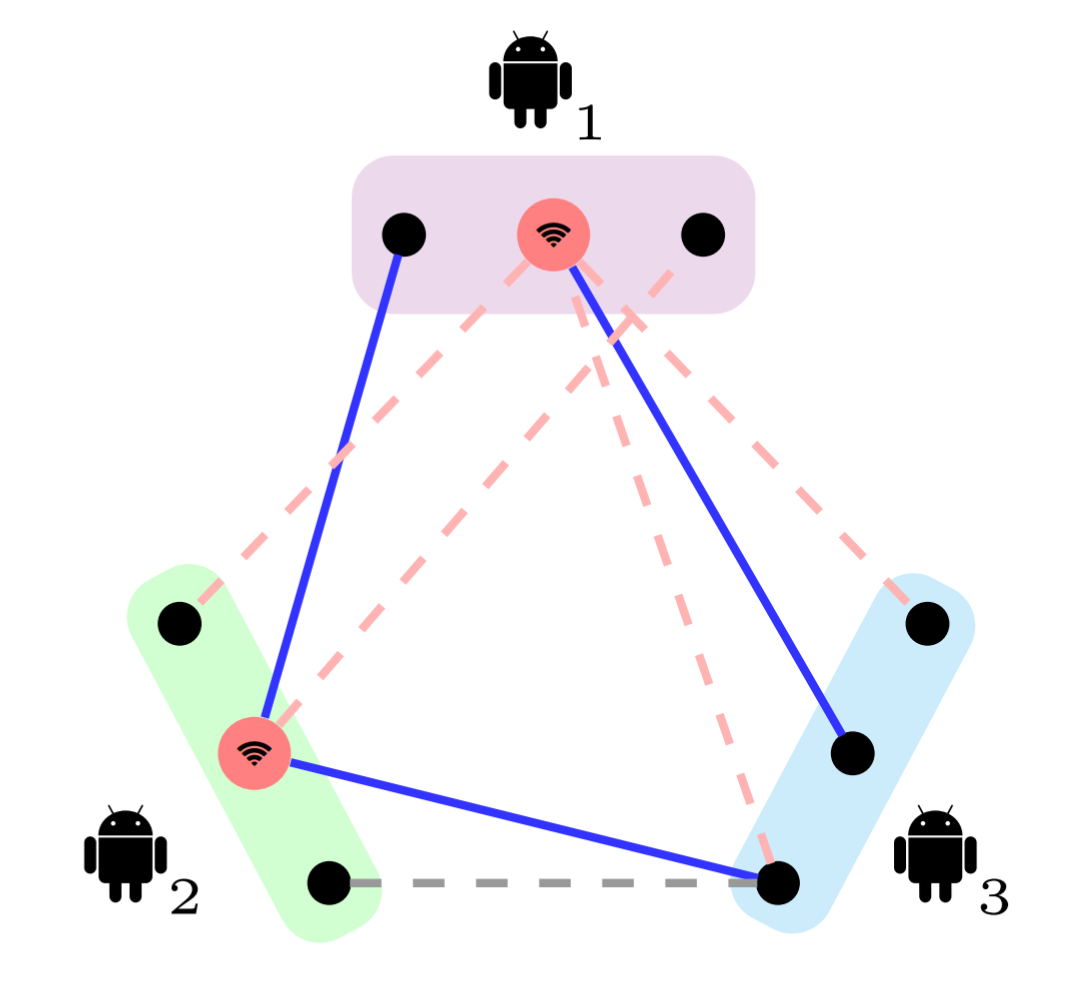
Int. Journal of Robotics Research (IJRR) 2020 — Invited Paper
- CLEAR: A Consistent Lifting, Embedding, and Alignment Rectification Algorithm for Multi-View Data Association –
K. Fathian, K. Khosoussi, Y. Tian, P. Lusk, and J.P. How
IEEE Transactions on Robotics (T-RO) 2020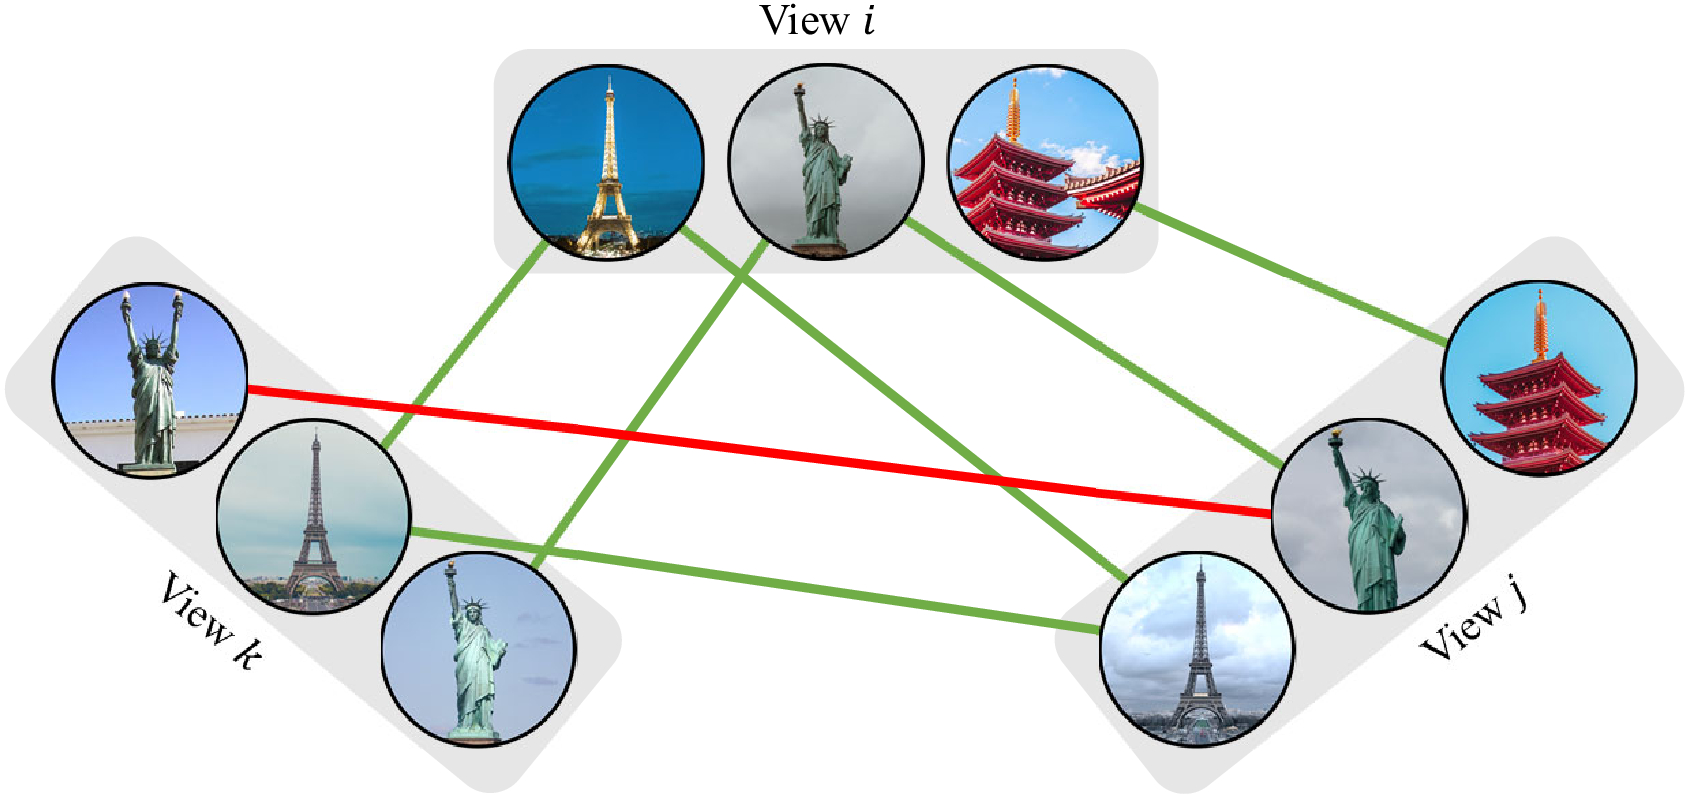
Source code:
- Reliable Graphs for SLAM –

K. Khosoussi, M. Giamou, G.S. Sukhatme, S. Huang, G. Dissanayake, and J.P. How
Int. Journal of Robotics Research (IJRR) 2019 — Invited Paper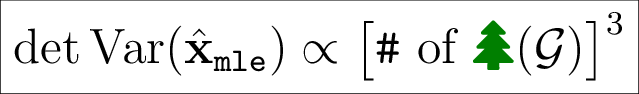
- A Sparse Separable SLAM Back-End —
K. Khosoussi, S. Huang, and G. Dissanayake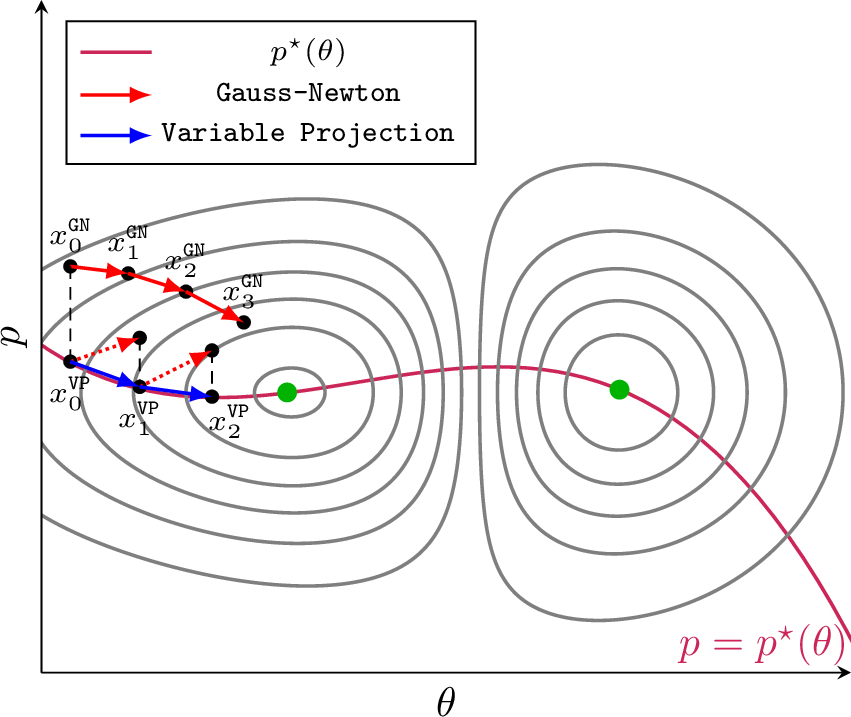
IEEE Transactions on Robotics (T-RO) 2016
Source code:
- Dimensionality Reduction for Point Feature SLAM Problems with Spherical Covariance Matrices – ScienceDirect
H. Wang, S. Huang, K. Khosoussi, U. Frese, G. Dissanayake, and B. Liu.
Automatica 2015
Conference Papers
- Non-Monotone Energy-Aware Information Gathering for Heterogeneous Robot Teams –
X. (J.) Cai, B. Schlotfeldt, K. Khosoussi, N. Atanasov, G.J. Pappas, J.P. How
IEEE Int. Conf. on Robotics and Automation (ICRA) 2021
- NF-iSAM: Incremental Smoothing and Mapping via Normalizing Flows
Q. Huang, C. Pu, D. Fourie, K. Khosoussi, J.P. How, J.J. Leonard
IEEE Int. Conf. on Robotics and Automation (ICRA) 2021
- Multi-Robot Distributed Semantic Mapping in Unfamiliar Environments through Online Matching of Learned Representations
S. Jamieson, K. Fathian, K. Khosoussi, J.P. How, Y. Girdhar
IEEE Int. Conf. on Robotics and Automation (ICRA) 2021
- Resource-Aware Algorithms for Distributed Loop Closure Detection with Provable Performance Guarantees –
Y. Tian++, K. Khosoussi++, and J.P. How
Int. Workshop on the Algorithmic Foundations of Robotics (WAFR) 2019
Note: ++ Equal contribution; Invited to IJRR - see the journal version.
- Near-Optimal Budgeted Data Exchange for Distributed Loop Closure Detection –
Y. Tian, K. Khosoussi, M. Giamou, J.P. How, and J. Kelly
Robotics: Science and Systems (RSS) 2018
Note: See the journal version.
Source code:
- Talk Resource-Efficiently to Me: Optimal Communication Planning for Distributed Loop Closure Detection –
M. Giamou++, K. Khosoussi++, and J.P. How
IEEE Int. Conf. on Robotics and Automation (ICRA) 2018
Note: ++ Equal contribution; Nominated for ICRA best multi-robot systems award
Source code:
- Designing Sparse Reliable Pose-Graph SLAM: A Graph-Theoretic Approach –
K. Khosoussi, G.S. Sukhatme, S. Huang, and G. Dissanayake
Int. Workshop on the Algorithmic Foundations of Robotics (WAFR) 2016
Note: Invited to IJRR - see the journal version.
- Tree-Connectivity: Evaluating the Graphical Structure of SLAM –
K. Khosoussi, S. Huang, and G. Dissanayake
IEEE Int. Conf. on Robotics and Automation (ICRA) 2016
Note: See the journal version.
- Exploiting the Separable Structure of SLAM – RSS Proceedings
K. Khosoussi, S. Huang, and G. Dissanayake
Robotics: Science and Systems (RSS) 2015
Note: See the journal version.
Source code:
- Novel Insights into the Impact of Graph Structure on SLAM –
K. Khosoussi, S. Huang, and G. Dissanayake
IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS) 2014
Note: See the journal version.
- Towards a Reliable SLAM Back-End –
G. Hu, K. Khosoussi, and S. Huang
IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS) 2013
- Monte Carlo Sampling of Non-Gaussian Proposal Distribution in RBPF-SLAM –
N. Marhamati, H.D. Taghirad, and K. Khosoussi
Australasian Conf. on Robotics and Automation (ACRA) 2012
Tutorials & Refereed Workshop Papers
- Good, Bad, and Ugly Graphs for SLAM –
K. Khosoussi, S. Huang, and G. Dissanayake
Robotics: Science and Systems (RSS) 2015 Workshop on The Problem of Mobile Sensors
Note: See the journal version.
- Past, Present and Future of SLAM –
K. Khosoussi and H.D. Taghirad
RSI/ISM Int. Conf. on Robotics and Mechantronics (ICRoM) 2013
Sharif University of Technology, Tehran, Iran
Theses
- Exploiting the Intrinsic Structures of Simultaneous Localization and Mapping –
K. Khosoussi
Ph.D. Thesis, 2017
Centre for Autonomous Systems
University of Technology Sydney
- Novel RBPF-SLAM Algorithms with Non-Gaussian Proposal Distributions –
K. Khosoussi
B.Sc. Thesis, 2011
ECE Department
K.N.Toosi University of Technology
Technical Notes
- Block-Coordinate Minimization for Large SDPs with Block-Diagonal Constraints –
Y. Tian, K. Khosoussi, and J.P. How
arXiv:1903.00597 [math.OC]
- On the Expected Value of the Determinant of Random Sum of Rank-One Matrices –
K. Khosoussi
arXiv:1702.08247 [cs.DS]
Note: see the journal version.
- Maximizing the Weighted Number of Spanning Trees: Near-t-Optimal Graphs –
K. Khosoussi, G.S. Sukhatme, S. Huang, and G. Dissanayake
arXiv:1604.01116 [cs.DS]
Note: see the journal version.